

Open-source multi-model AI problem solving: independent answers, critique, convergence, human-gated execution, and provenance from idea to outcome.
- ✓Open-source license (MIT)
- ✓Actively maintained (<30d)
- ✓Clear description
- ✓Topics declared
- ✓Documented (README)
git clone https://github.com/spacepacket1/e3d-pilot && cp e3d-pilot/*.md ~/.claude/agents/Subagents overview
# e3d-pilot
**Multi-model AI problem solving: independent answers → critique → convergence → human decision → execution → review → provenance.**
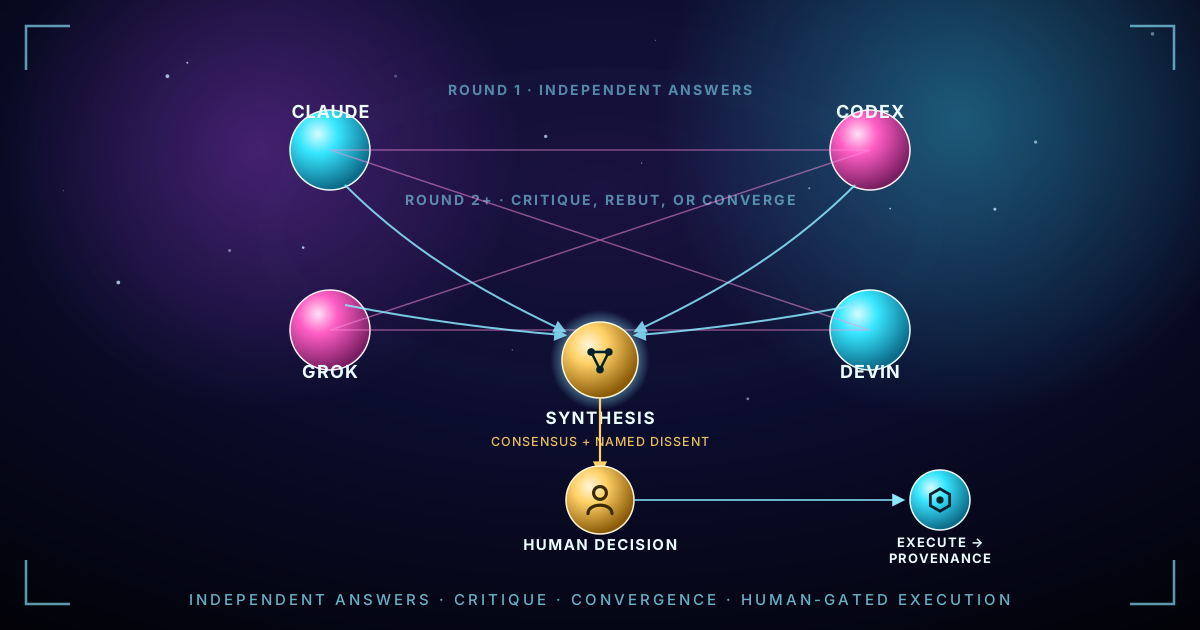
e3d-pilot is an open-source system for getting multiple AI models to work on the same problem instead of trusting a single model's answer — from a one-off question to a fully executed, human-gated software change.
It starts simply. Ask several configured models (Claude, Codex, Grok, Devin, or others you wire in) the same question. Let them answer independently, see and critique each other's positions, revise, expose real dissent, and converge on the strongest answer. That's `bin/e3d-debate` — a standalone tool, no repo or pipeline required. It's also available inside your editor as an MCP server: [use it from GitHub Copilot, Claude Code, or Cursor](#use-e3d-pilot-from-github-copilot-claude-code-and-cursor-mcp) with one `npx` line.
Then e3d-pilot takes the same instinct further, into real software work: `discover → ideate → approve → draft → negotiate → execute → review → publish → outcome`. Every step is preserved in an append-only ledger, so the system (or a human, or a fresh AI session) can later reconstruct where an idea came from, which models or people influenced it, what it produced, and what happened afterward.
## Try e3d-debate in 60 seconds
```bash
git clone https://github.com/spacepacket1/e3d-pilot.git
cd e3d-pilot
bin/e3d-debate \
"Should e3d-pilot's provenance data be a graph, or is that over-engineering?" \
--providers claude,codex --rounds 3
```
(Any `lib/providers/<name>` adapter can join — add `devin`/`grok-build`/others if you have them configured; `claude`/`codex` are the two most people trying this will already have.)
Round 1: every provider answers independently. Round 2+: each sees the others' prior-round positions and must defend, revise, rebut, or concede. The debate stops early if they genuinely converge; a synthesizer then reads the full transcript and reports a final answer, consensus, and any remaining dissent.
That question isn't hypothetical — it's a real debate we ran this way, condensed from the [full transcript](docs/debates/2026-09-07-e3d-graph-generalization/transcript.md):
```text
QUESTION
Should the E3D 3D graph generalize into a standalone product, or should
e3d-pilot instrument its own provenance instead?
CLAUDE (round 3, the only one to formally reach "approved")
Don't create e3d-graph yet — build a confidence-annotated, domain-neutral
provenance emitter inside e3d-pilot, prove attribution questions are
answerable from the data alone, add a 2D lens only if they are, and extract
a public repo only on external pull or paid demand.
CODEX (round 3)
Build outcome-linked Pilot provenance first, then open-source a narrow
standalone viewer only if measured workflow value and external pull
justify extraction.
DEVIN (round 3)
Instrument Pilot with a domain-neutral provenance schema from day one; gate
public extraction on the internal experiment succeeding, not on indefinite
deferral.
GROK-BUILD (round 3)
Do not ship standalone e3d-graph; instrument Pilot provenance first and
treat visualization as a 2D lens inside E3D.
SYNTHESIS
Do not ship a standalone e3d-graph product. Instrument e3d-pilot now with
an append-only, domain-neutral, confidence-annotated provenance schema —
the ledger stays canonical, the graph is an index, not memory. Validate by
answering real attribution questions from the data alone before any UI.
DISSENT (reported, not hidden)
Devin and partly Codex would gate public extraction on the internal
experiment succeeding; Claude and Grok-build require external pull or paid
demand instead — a real, named disagreement the tool didn't paper over.
```
**What happened next:** we built exactly that, then ran it against three real ideas in this repo's own history. All three came back "more useful than reading the raw ledger by hand" — and one of them caught a real error in the spec that proposed it. Later graph-intelligence queries were evaluated just as honestly: one clear win, two explicitly "no signal" because the real data was still too sparse — reported as-is, not oversold. That full arc (spec, dogfood results, the honest misses) is in [`docs/provenance-graph-experiment.md`](docs/provenance-graph-experiment.md) and [`docs/graph-intelligence-experiment.md`](docs/graph-intelligence-experiment.md).
**Experimental: the provenance graph.** e3d-pilot now derives structural relationships — ideas, actors, models, decisions, repos, commits, evidence, outcomes — from its own immutable event ledger. We're testing whether that graph reveals patterns that are genuinely hard to get from the raw ledger, not claiming it already does.
You don't need the rest of e3d-pilot to use `e3d-debate` on its own — see [e3d-debate](#e3d-debate-experimental) below for the full flag reference. Keep reading for the part that takes a debate's answer all the way to a shipped, reviewed, provenance-tracked change.
## Use e3d-pilot from GitHub Copilot, Claude Code, and Cursor (MCP)
`e3d-mcp` is a zero-dependency [Model Context Protocol](https://modelcontextprotocol.io) server. It lets an AI coding assistant ask for a multi-model second opinion mid-task, instead of committing to the first answer one model gives it. It's published on npm as [`e3d-pilot`](https://www.npmjs.com/package/e3d-pilot) and listed in the official MCP registry as `io.github.spacepacket1/e3d-pilot`.
| Tool | What it does |
| --- | --- |
| `e3d_debate` | Several independent models answer and a synthesizer returns a decisive answer, a consensus level (`full` / `majority` / `split`), any named dissent, and each model's final position, as both readable text and structured data (`dissent.present`, `dissent.summary`, `positions`). `mode: "quick"` (default) is one round and takes seconds; `mode: "thorough"` adds a critique round where models rebut each other. The full transcript is opt-in (`include_transcript`). |
| `e3d_list_providers` | Shows which model providers are available on this machine. A debate needs at least two. |
| `e3d_provenance_trace` | Read-only: traces why a change exists, from its origin through debates, approvals, execution, review, and outcome. |
| `e3d_ideas_list` | Read-only: lists the ideas e3d-pilot tracks in a repo, to find an id for the trace. |
A real result in `quick` mode (11 seconds, two models), from asking whether a small CLI should default to a flat JSON file or SQLite:
```text
FINAL ANSWER: Default to a flat JSON file for a small CLI. It has no dependencies, is
human-readable and diffable, and is easy to hand-edit and debug. Write it atomically
(temp file, then rename). Move to SQLite once you need indexed queries, concurrent
writers, or data beyond a few MB.
CONSENSUS: split
DISSENT: Codex prefers SQLite as the default for any persistent mutable state because
it gives transactions, concurrency safety, and schema evolution at low cost.
```
The disagreement is the point: you get the answer and the strongest case against it, instead of one model's confident guess.
### Install
**VS Code (GitHub Copilot agent mode):** [one-click install](https://insiders.vscode.dev/redirect/mcp/install?name=e3d-pilot&config=%7B%22command%22%3A%22npx%22%2C%22args%22%3A%5B%22-y%22%2C%22--no-update-notifier%22%2C%22-p%22%2C%22e3d-pilot%22%2C%22e3d-mcp%22%5D%7D), or add this to `.vscode/mcp.json`:
```json
{
"servers": {
"e3d-pilot": { "type": "stdio", "command": "npx", "args": ["-y", "--no-update-notifier", "-p", "e3d-pilot", "e3d-mcp"] }
}
}
```
**Claude Code:**
```bash
claude mcp add e3d-pilot -- npx -y --no-update-notifier -p e3d-pilot e3d-mcp
```
**Cursor** (`~/.cursor/mcp.json`) and other clients that use the `mcpServers` shape:
```json
{ "mcpServers": { "e3d-pilot": { "command": "npx", "args": ["-y", "--no-update-notifier", "-p", "e3d-pilot", "e3d-mcp"] } } }
```
Any MCP client that can launch a stdio server should work; the shapes above are each client's standard format.
**Prerequisites:** Node 18+, `jq`, bash 4+ (macOS ships 3.2: `brew install bash jq`), and at least two model CLIs logged in (e.g. `claude` and `codex`). Check them all at once:
```bash
npx -y -p e3d-pilot e3d-mcp --doctor
```
`--doctor` reports what's missing and how to fix it. It does not need the full pipeline's `e3d-code` executor (it only notes whether that is installed). From a clone, `bin/e3d-mcp --print-config --local` prints a config that points at your checkout.
### Using it
In Copilot agent mode (or any client), ask: *"Before you pick a storage layer, run e3d_debate on SQLite vs flat JSON for this CLI."* To make the assistant do this unprompted for contestable design choices, copy [examples/copilot-instructions.md](examples/copilot-instructions.md) into `.github/copilot-instructions.md` or `AGENTS.md`. Don't use it for lookups or questions with an obvious answer; it is slow and costs money.
### Cost and limits
- `quick` debates take seconds to a minute and `thorough` ones a few minutes; both spend **your** model credits. The server caps `e3d_debate` with `E3D_MCP_MAX_ROUNDS` (3), `E3D_MCP_MAX_PROVIDERS` (4), `E3D_MCP_MAX_CONCURRENT` (2), and `E3D_MCP_TIMEOUT_SEC` (900).
- It uses whatever provider CLIs and keys are in the server's environment (see `e3d-pilot providers list`).
- The Copilot *coding agent* runs on GitHub-hosted runners, where those provider CLIs aren't installed. Use the local (stdio) setup above for now.
- `e3d_debate` and the read-only tools never write to a repo. The pipeline tools below do, only through the same gated CLI paths as a person would, and `e3d_pilot_propose` writes to the repo's `.e3d-pilot/` ledger.
### Run the pipelWhat people ask about e3d-pilot
What is spacepacket1/e3d-pilot?
+
spacepacket1/e3d-pilot is subagents for the Claude AI ecosystem. Open-source multi-model AI problem solving: independent answers, critique, convergence, human-gated execution, and provenance from idea to outcome. It has 1 GitHub stars and its last recorded update is dated 2026-10-17.
How do I install e3d-pilot?
+
You can install e3d-pilot by cloning the repository (https://github.com/spacepacket1/e3d-pilot) or following the README instructions on GitHub. ClaudeWave also provides quick install blocks on this page.
Is spacepacket1/e3d-pilot safe to use?
+
Our security agent has analyzed spacepacket1/e3d-pilot and assigned a Trust Score of 95/100 (tier: Verified). See the full breakdown of passed checks and flags on this page.
Who maintains spacepacket1/e3d-pilot?
+
spacepacket1/e3d-pilot is maintained by spacepacket1. The last recorded GitHub activity is dated 2026-10-17, with 3 open issues.
Are there alternatives to e3d-pilot?
+
Yes. On ClaudeWave you can browse similar subagents at /categories/agents, sorted by popularity or recent activity.
Deploy e3d-pilot to your cloud
Ship this repo to production in minutes. Each platform spins up its own environment with editable env vars.
Maintain this repo? Add a badge to your README
Drop the badge into your GitHub README to show it's tracked on ClaudeWave. Each badge links back to this page and reflects the live Trust Score.
[](https://claudewave.com/repo/spacepacket1-e3d-pilot)<a href="https://claudewave.com/repo/spacepacket1-e3d-pilot"><img src="https://claudewave.com/api/badge/spacepacket1-e3d-pilot" alt="Featured on ClaudeWave: spacepacket1/e3d-pilot" width="320" height="64" /></a>More Subagents

The agent harness performance optimization system. Skills, instincts, memory, security, and research-first development for Claude Code, Codex, Opencode, Cursor and beyond.

The agent that grows with you

Makes your AI agent think like the laziest senior dev in the room. The best code is the code you never wrote.

Java 面试 & 后端通用面试指南,覆盖计算机基础、数据库、分布式、高并发、系统设计与 AI 应用开发

Build Agentic workflows, RAG pipelines, with rich AI model and tool support on one collaborative workspace. Deploy on cloud, VPC, or self-hosted, so teams move from prototype to production without rebuilding the stack.

The agent engineering platform.